Kerem Yildirir

Deep Learning / Computer Vision

I work as a Deep Learning Engineer at Ramblr.ai, where we build AI for the physical world. I focus on automated video annotation flows that help teach AI agents to understand real-world processes, from strawberry harvesting to industrial quality control. On my free time, I enjoy tinkering with Linux systems, experimenting with specialty coffee, hiking, playing the drums, and going down random rabbit holes.
Kerem Yildirir profile image

Experience

Deep Learning Engineer Ramblr.ai
Mar 2024 – Present
Python PyTorch Ray VLMs Active Learning Object Detection Tracking Action Recognition
  • Built auto-annotation pipelines with state-of-the-art VLMs and vision models, cutting annotation effort by 70–95%
  • Architected an active learning framework from scratch for continuous model improvement
  • Trained and deployed detection, tracking and action recognition models with Ray across robotics, automotive and agriculture projects
AI Consultant Netlight Consulting
Dec 2022 – Mar 2024
MLOps Python AWS Triton Inference Server Docker
  • Built an ML serving pipeline for a leading medical company, turning 3D scan segmentation and classification into automated reports
  • Cut processing time 12× (120s → 10s per scan); the architecture was adopted internally as a reusable project template
  • Led 2 internal Triton Inference Server workshops for ~20 engineers
Machine Learning Engineer Isarsoft
Oct 2021 – Oct 2022
Python C++ TensorRT Triton Inference Server Object Detection Multi-Object Tracking NVIDIA Jetson
  • Trained real-time person detection and multi-object tracking models
  • Deployed them on NVIDIA Jetson edge devices with Triton Inference Server and TensorRT
  • Enabled real-time video analytics at the edge
Computer Vision Engineer FRM II
Oct 2020 – Oct 2021
C++ CUDA Python Linux Image Processing
  • Ported a Python neutron image segmentation pipeline to C++/CUDA at Germany’s largest research neutron source
  • Achieved a 100× speedup (200ms → 2ms per image)
  • Made processing terabyte-scale datasets possible for the first time
Computer Vision Engineer WARP
Apr 2020 – Sep 2020
Python Object Detection Multi Object Tracking ROS
  • Built a real-time 3D object detection and tracking pipeline for autonomous driving
  • Lifted 2D detections into 3D point clouds using sensor fusion
  • Gave an autonomous vehicle full spatial awareness of its surroundings

Education

Oct 2019 - Sept 2022
GPA: 1.7
Thesis: “Probabilistic Object Detection and Reconstruction from a single RGB-D frame”
B.Sc. Computer Science and Engineering Sabanci University
Sept 2015 - June 2019
GPA: 1.4
Thesis: “Plant Disease Classification”

Blog

From Research to Production I: Efficient Model Deployment with Triton Inference Server
From Research to Production I: Efficient Model Deployment …

With the recent developments in the field of artificial intelligence, a lot of new use cases are emerging. Developing …

Projects

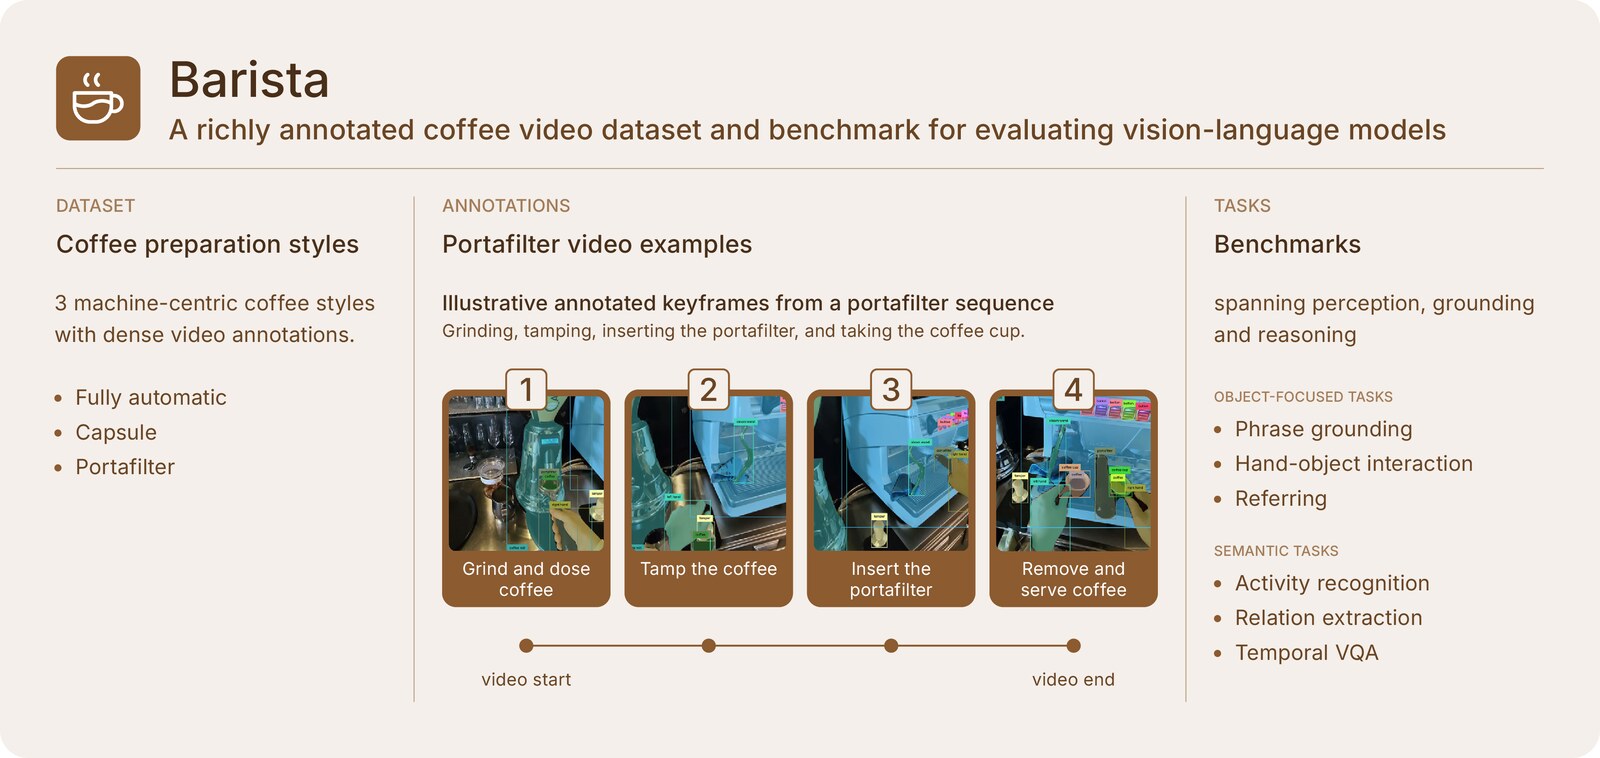
BARISTA: A Multi-Task Egocentric Benchmark for Compositional Visual Understanding
Computer Vision VLMs Benchmark
BARISTA: A Multi-Task Egocentric Benchmark for …

Scene understanding is central to general physical intelligence, and video is a primary modality for …

Show2Instruct
LLMs Python Blender
Show2Instruct

Show2Instruct enhances LLMs with spatial understanding to validate building plans against …

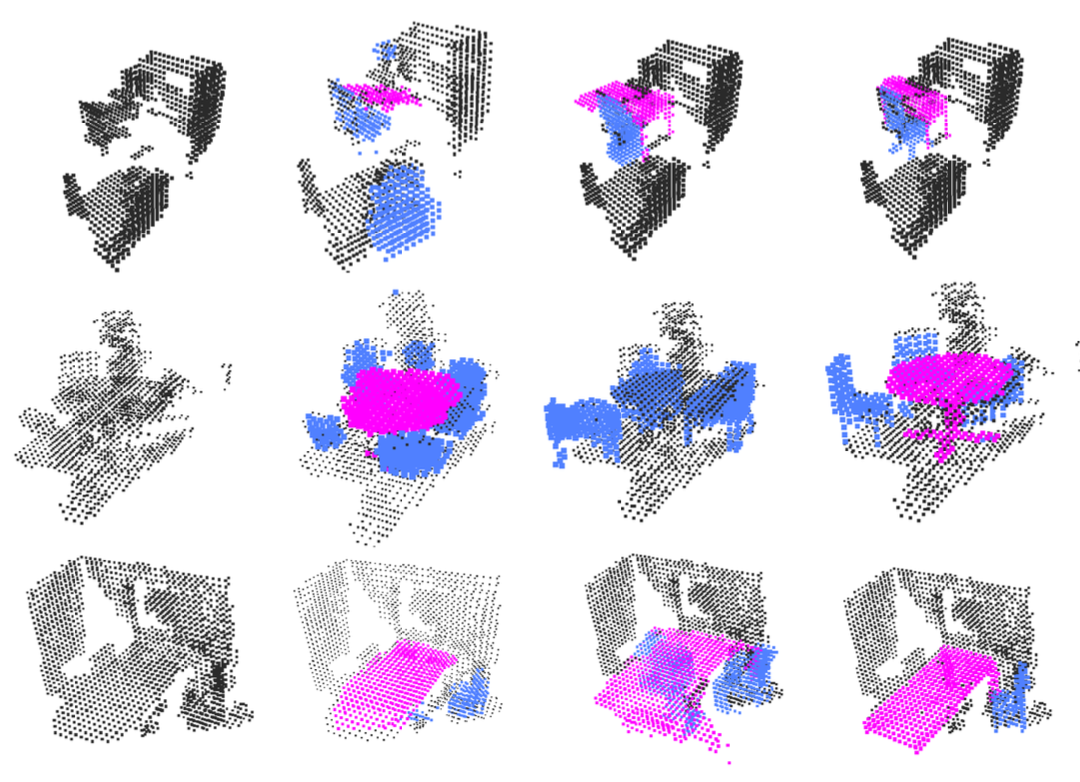
Probabilistic Object Detection and Reconstruction from a single RGB-D frame
Machine Learning Computer Vision
Probabilistic Object Detection and Reconstruction …

Semantic scene understanding is crucial aspect of modern day robotic applications. With the recent …

Monte Carlo Dropout for Object Detection on Point Clouds
Machine Learning Computer Vision
Monte Carlo Dropout for Object Detection on Point …

In this work, we take VoteNet, a state-of-the-art deep neural network for object detection, as a …

Indirect Visual Odometry With Optical Flow
Computer Vision C++
Indirect Visual Odometry With Optical Flow

Extending a Stereo camera Visual Odometry implementation with Optical Flow per the paper by Usenko …

Analysis and Experiments on Deep Closest Points Architecture
Machine Learning Computer Vision
Analysis and Experiments on Deep Closest Points …

The goal of the project was to conduct experiments and analyze their results on the DCP architecture …

3D Real-Time Instance Segmentation with LDLS-YOLACT
Machine Learning Computer Vision Python ROS
3D Real-Time Instance Segmentation with …

In this project I’ve developed a 3D object detection and tracking pipeline for autonomous …

KinectFusion: Dense Surface Mapping and Tracking
Computer Vision C++ CUDA
KinectFusion: Dense Surface Mapping and Tracking

Implementation of the paper KinectFusion by Microsoft using C++ and CUDA. The goal of the project is …

Multiple Object Tracking with Tracktor++
Machine Learning Computer Vision
Multiple Object Tracking with Tracktor++

Implemented vanilla Tracktor with Faster-RCNN using PyTorch. Added a basic motion model and also a …

Divergence-Free Shape Correspondence with Time Dependent Vector Fields
Computer Vision
Divergence-Free Shape Correspondence with Time …

We extended the paper “Divergence-Free Shape Correspondence by Deformation” and …

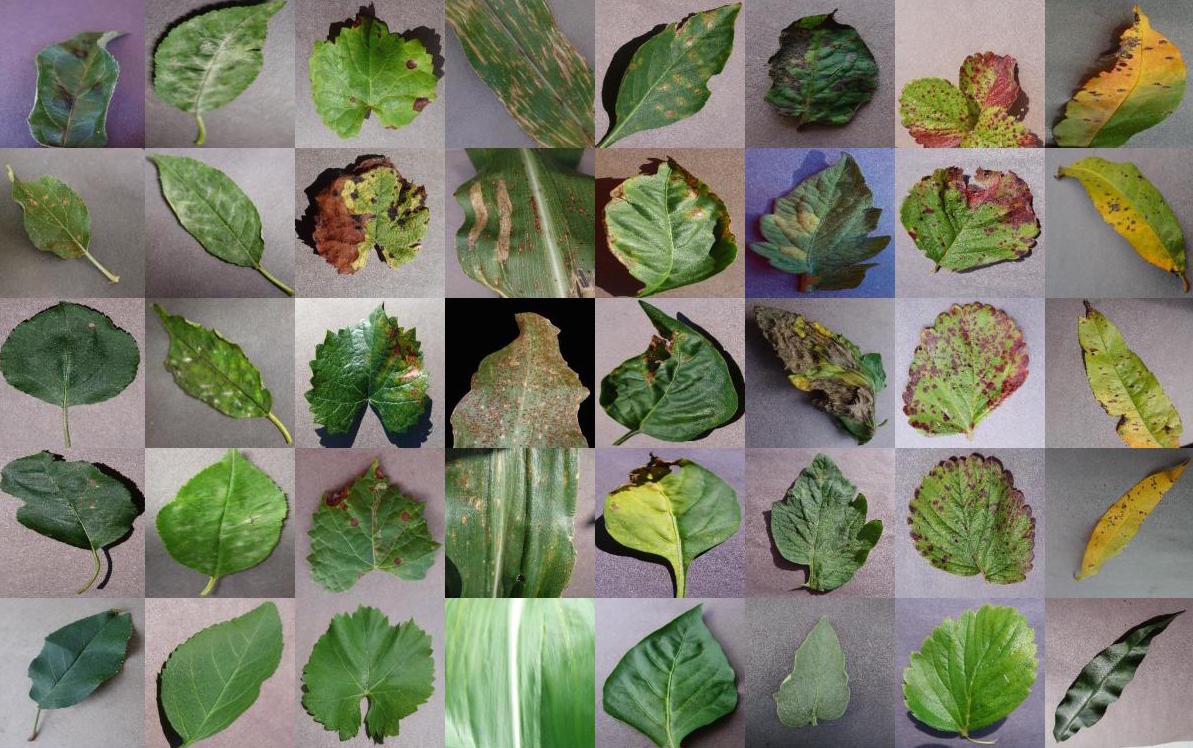
Plant Disease Classification
Machine Learning Computer Vision
Plant Disease Classification

Detection of plant diseases via computer vision based systems are being used to identify plant …

One Table to Count Them All: Parallel Frequency Estimation on Single-Board Computers
High Performance Computing
One Table to Count Them All: Parallel Frequency …

Sketches are probabilistic data structures that can provide approximate results within …

Plant Identification with Deep Learning Ensembles
Machine Learning Computer Vision
Plant Identification with Deep Learning Ensembles

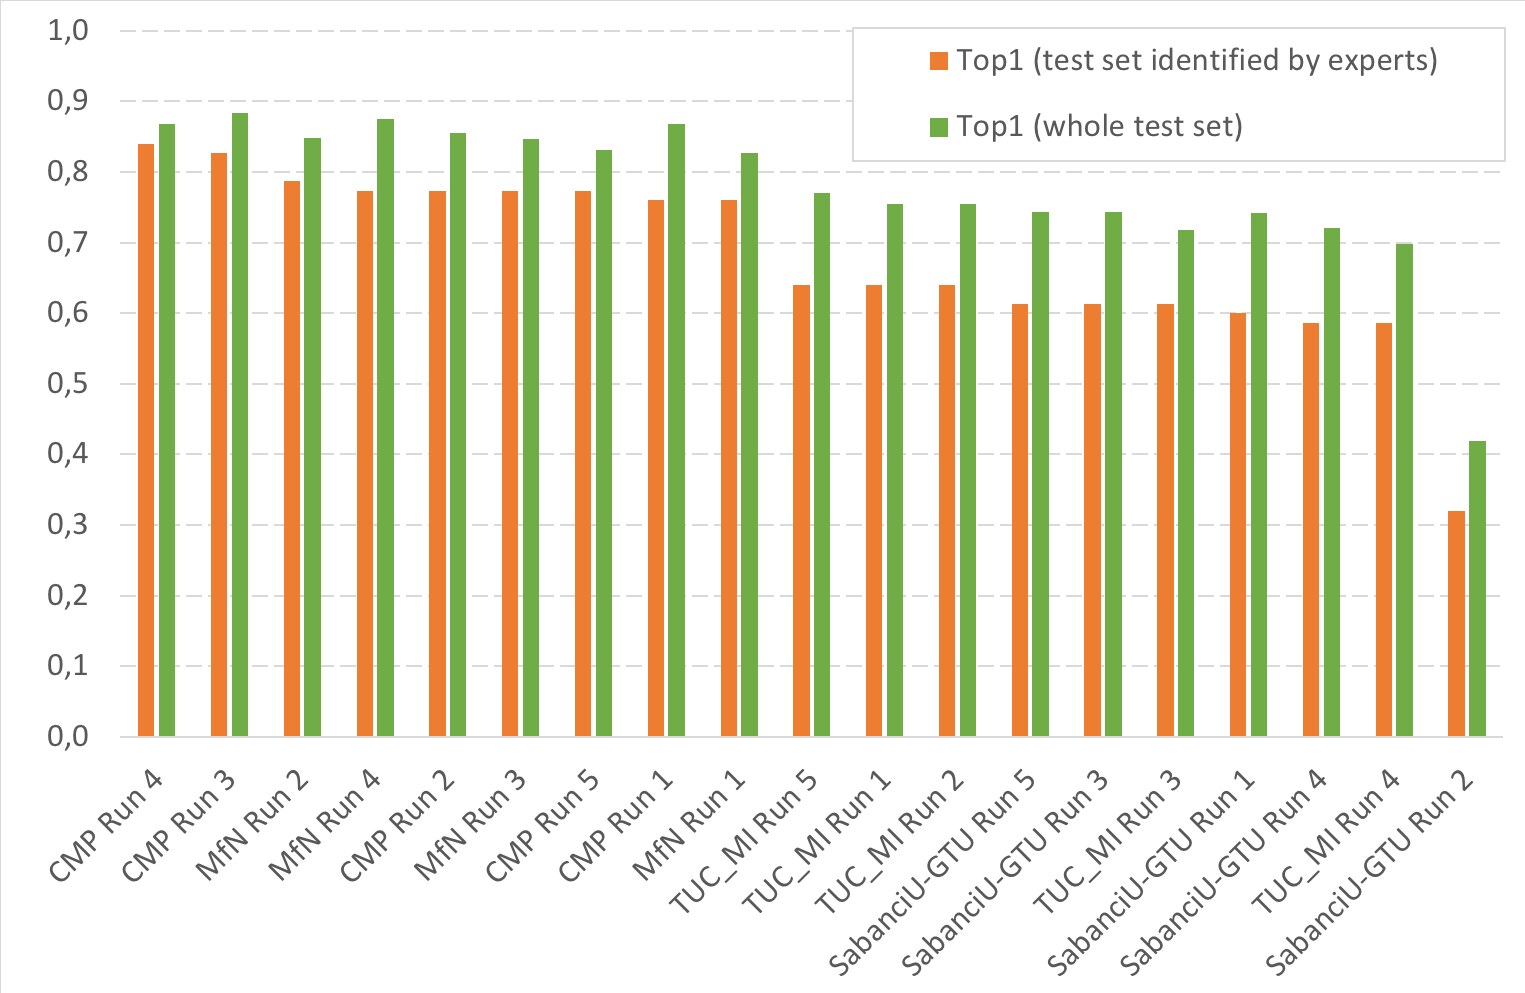
This work describes the plant identification system that we submitted to the ExpertLifeCLEF plant …