Computer Vision
Indirect Visual Odometry …
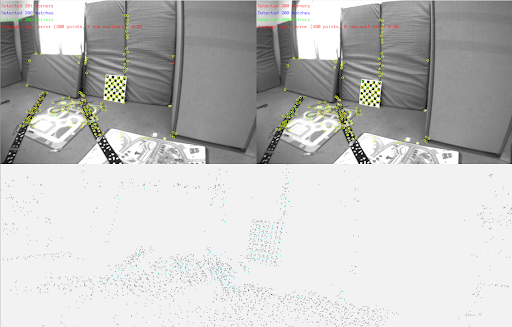
Extending a Stereo camera Visual Odometry implementation with Optical Flow per the paper by Usenko et al. Optical flow was used to track detected Keypoints through frames and again was used to carry them to the other camera to triangulate 3D points in the map.
- Initial implementation of a stereo …
Analysis and Experiments …
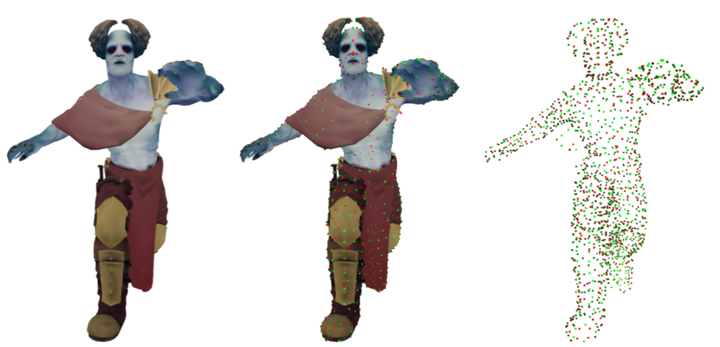
The goal of the project was to conduct experiments and analyze their results on the DCP architecture by Wang et al. Mixamo dataset was used to retrain the model and some tests were also done with the TUM RGBD dataset. Tried adding different regularizations, adding color as an additional input …
3D Real-Time Instance …
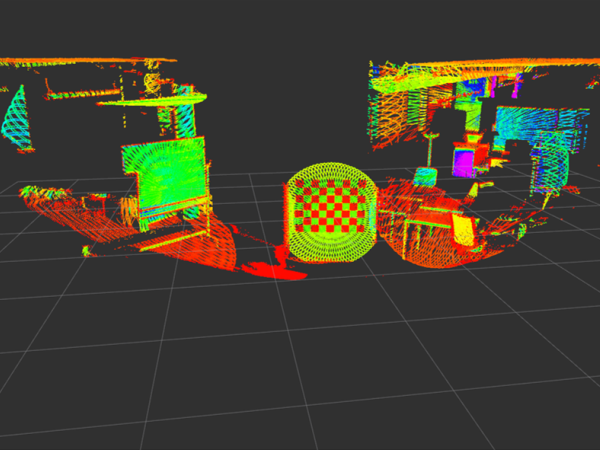
In this project I’ve developed a 3D object detection and tracking pipeline for autonomous driving with Python and ROS without any labeled 3D data. Our hardware were only a Livox mid-100 lidar sensor and a RealSense camera. After calibrating the sensors, the pipeline is as follows:
- Get 2D …