Machine Learning
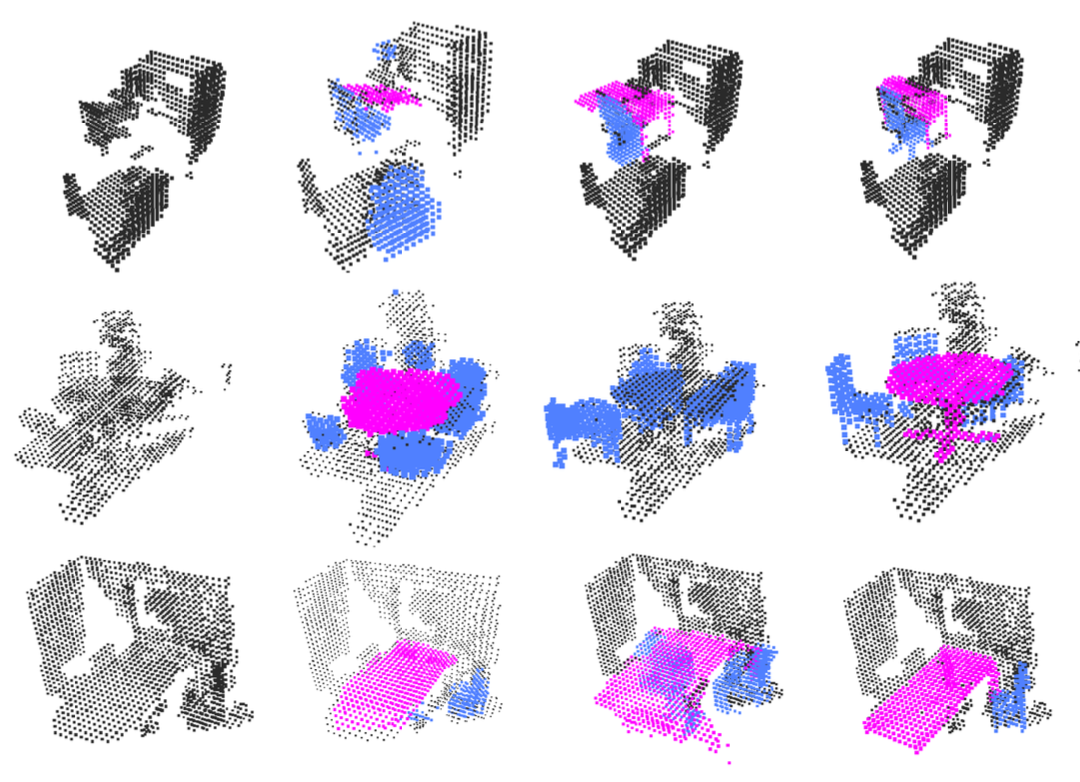
Probabilistic Object …
Semantic scene understanding is crucial aspect of modern day robotic applications. With the recent advances in deep learning and the increased availability of large scale richly annotated datasets, popularity of 3D scene understanding tasks has increased rapidly. In this work, we present a …
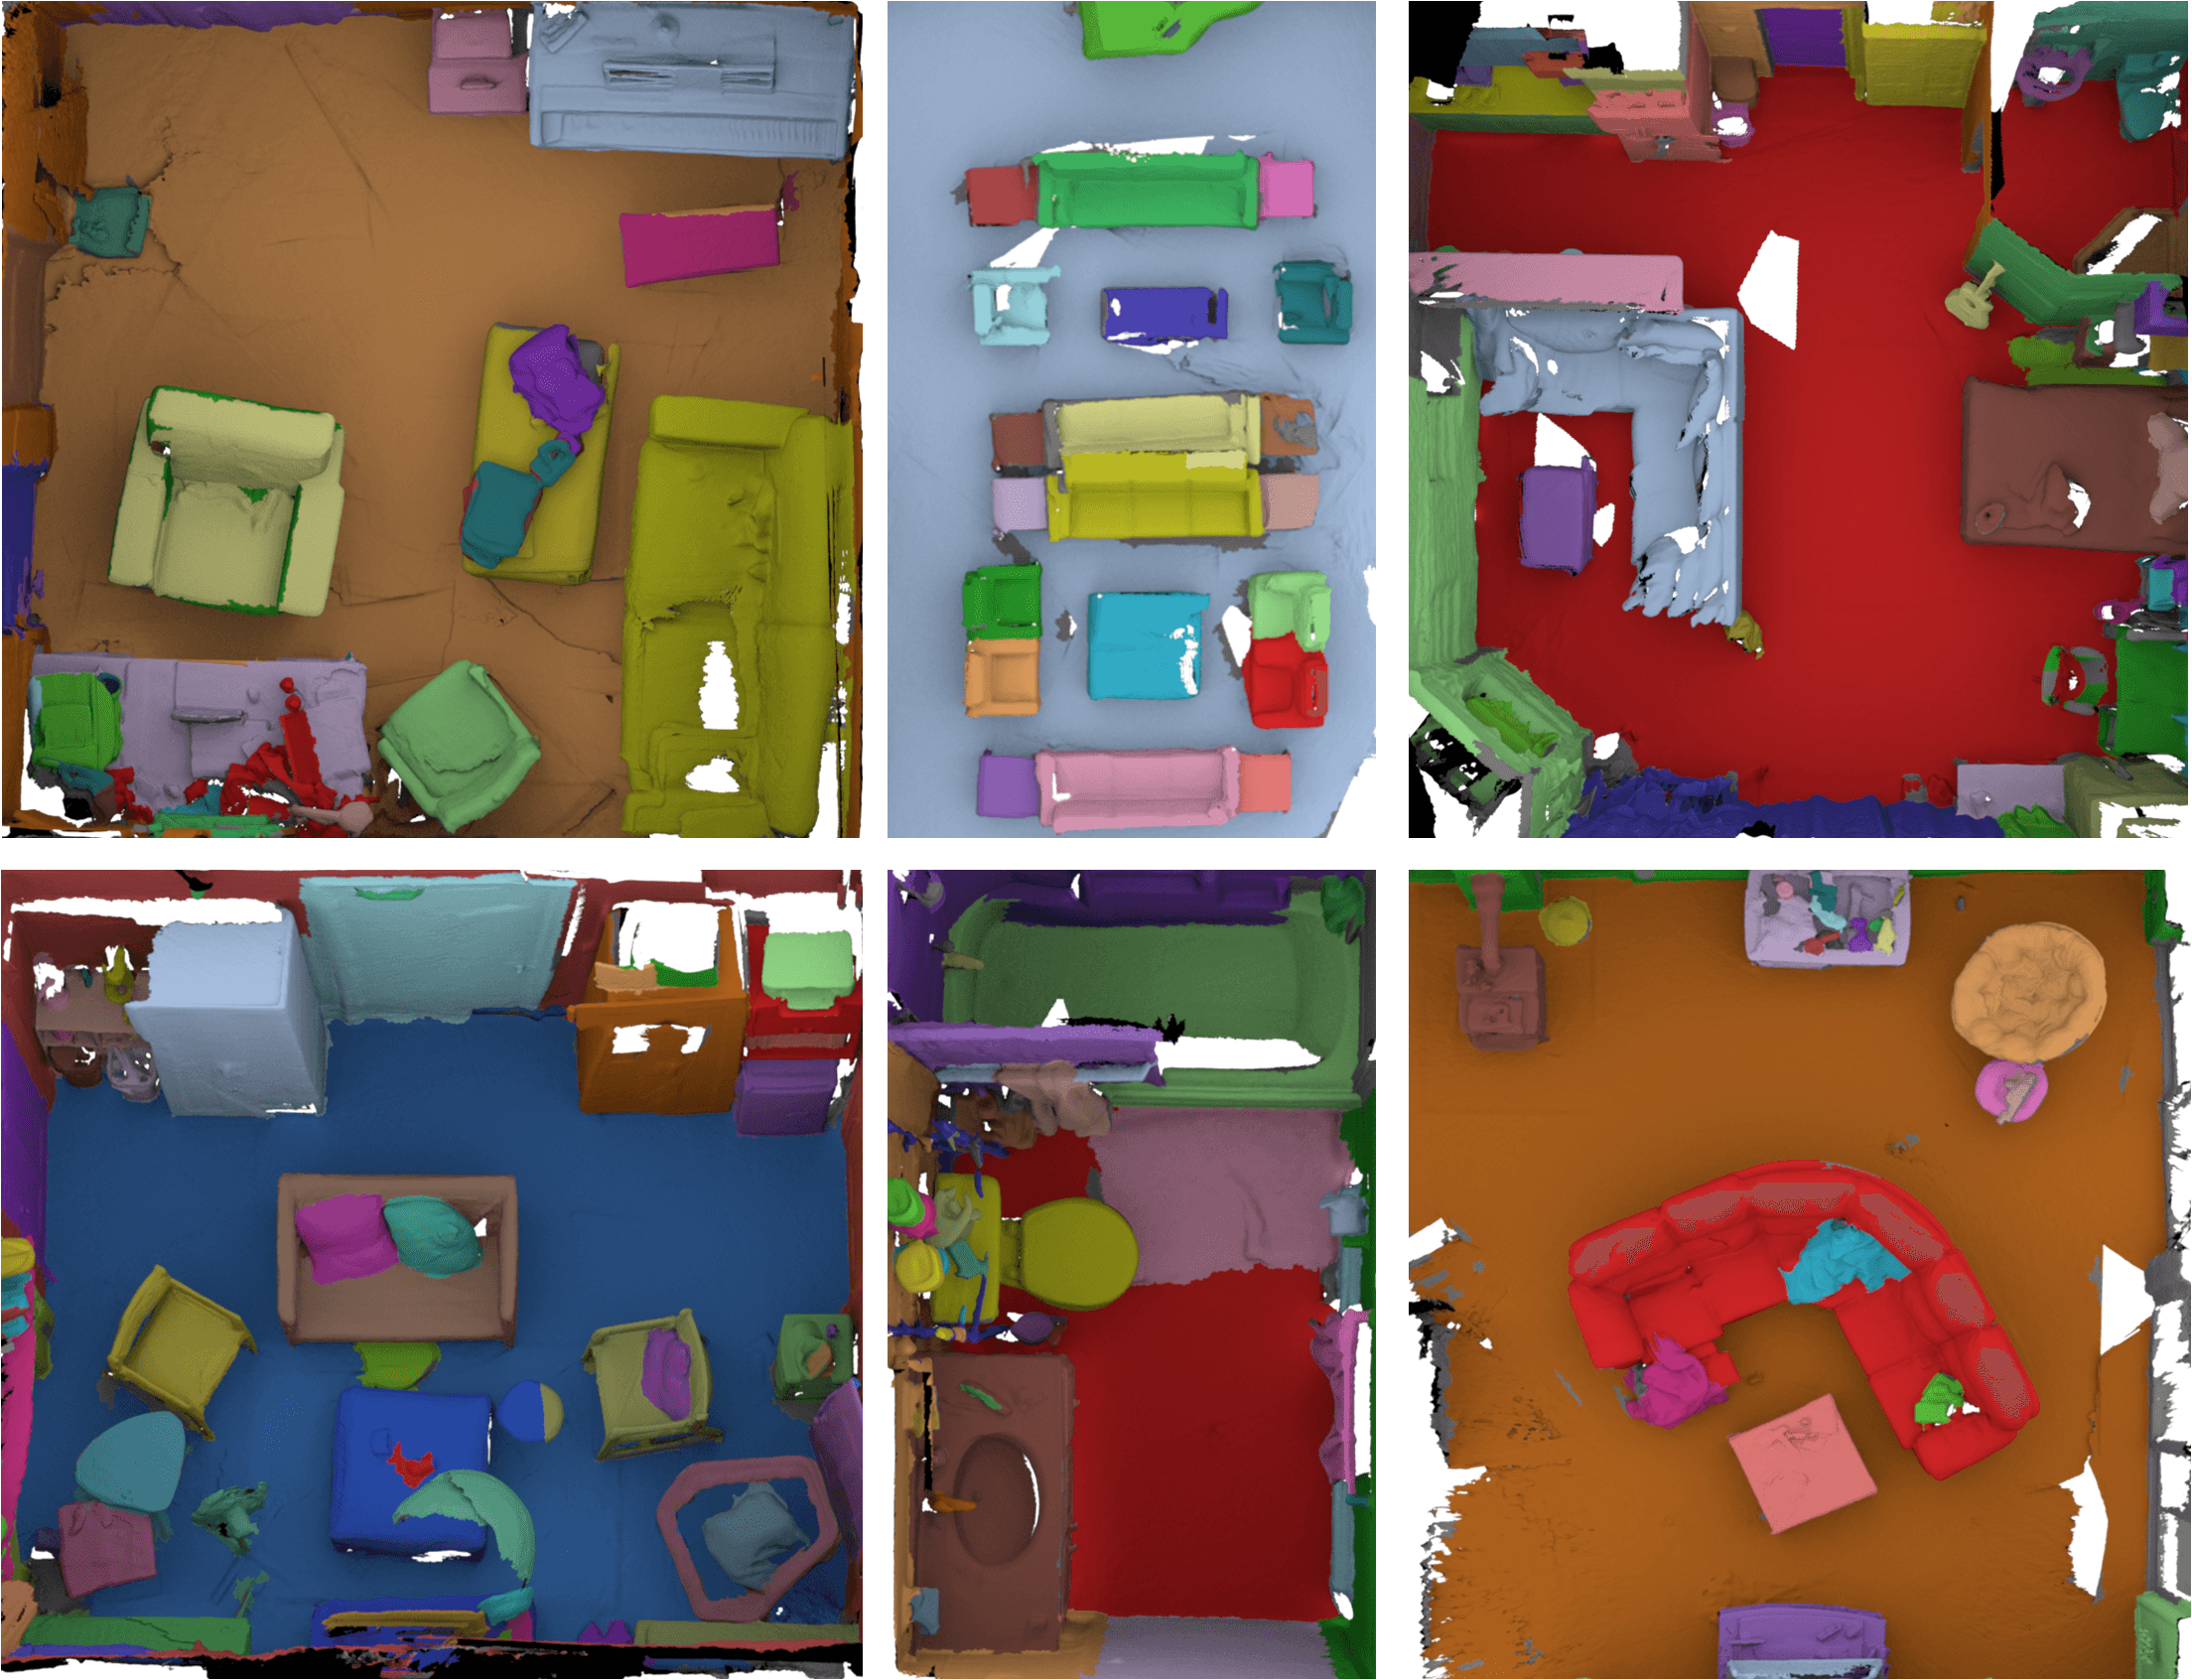
Monte Carlo Dropout for …
In this work, we take VoteNet, a state-of-the-art deep neural network for object detection, as a basis and extend it for computing epistemic uncertainty in its predictions with Monte Carlo dropout. We show that this quantity can be used as a weighting factor for predictions, leading to an increase …
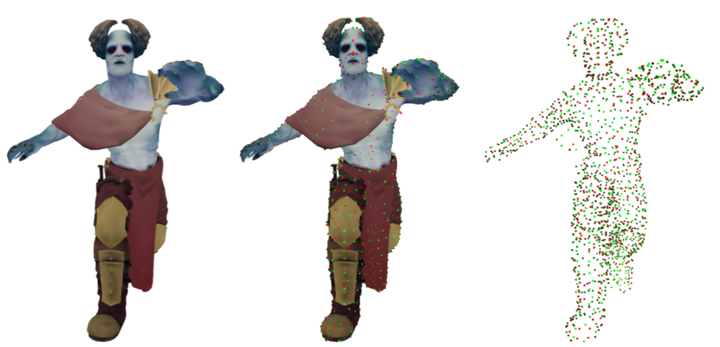
Analysis and Experiments …
The goal of the project was to conduct experiments and analyze their results on the DCP architecture by Wang et al. Mixamo dataset was used to retrain the model and some tests were also done with the TUM RGBD dataset. Tried adding different regularizations, adding color as an additional input …